

iFMH Series Joint Modules
Highly Integrated Joint Module: The 'Muscles and Bones' of Robots
iFMH Series Rotary Joint Module
Aligned with the industry trend toward high-density integrated drive architectures, the iFMH humanoid rotary joint module adopts a highly integrated design that seamlessly fuses a frameless torque motor, precision gearbox, high-resolution feedback sensor, and drive control circuit into a single precision mechanical unit. This all-in-one joint solution thoroughly eliminates the tedious procedures of independent component matching, selection, and debugging for developers. Featuring a plug-and-play 'turnkey' hardware format, it significantly reduces system integration complexity, providing a solid foundation for the overall design of high-dynamic and highly compact humanoid robots.
Product Model
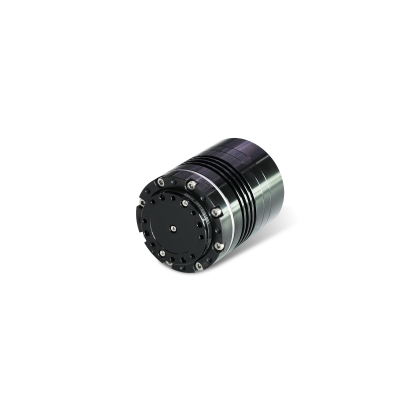
iFMH55H
Add comparison
Cancel comparison
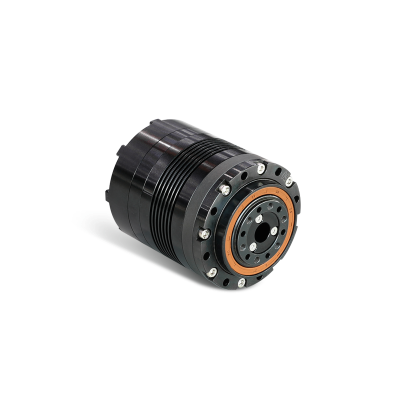
iFMH60H
Add comparison
Cancel comparison
iFMH70H
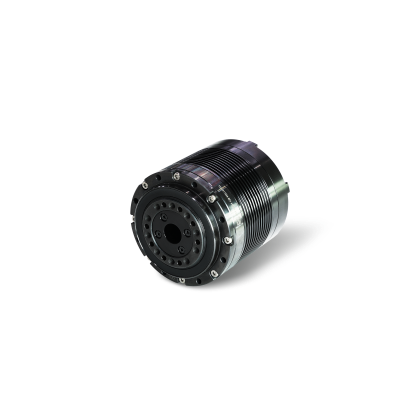
Add comparison
Cancel comparison
iFMH80H
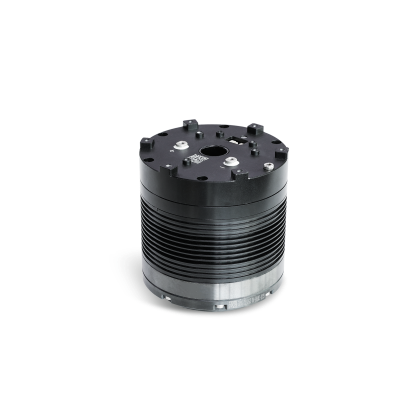
Add comparison
Cancel comparison
Slide to display more
Electrical Specifications
Fold up
Expand
Rated Voltage(VDC)
48
48
48
48
Gear Ratio
100:1
100:1
100:1
101:1
Peak Start-Stop Torque(N.m)
19
37
57
70
Rated Torque(N.m)
7.7
27
34
51
Maximum Momentary Torque(N.m)
35
71
95
143
Rated Speed(rpm)
37
35
31
35
Maximum No-Load Speed (rpm)
50
48
38
45
Rated Power(W)
29.8
99
110.4
186.9
Peak Torque Density(Nm/kg)
79
109
117
127
Input Voltage Range(VDC)
20~72
20~72
20~72
20~72
Encoder Type
Absolute Encoder
Absolute Encoder
Absolute Encoder
Absolute Encoder
Encoder Resolution
19-bit
19-bit
19-bit
19-bit
Dimensions(mm)
Φ55*70
Φ62*76
Φ70*76
Φ80*84
Hollow Bore Diameter(mm)
Φ8.4
Φ8.5
Φ12
Φ16
Weight(g)
445
650
815
1130